Brian Surgenor
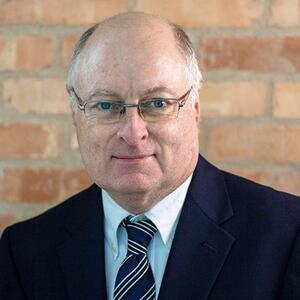
Brian Surgenor
Professor
Manufacturing automation, Machine vision for inspection, Pneumatic servosystems, Mechatronics education
Mechanical and Materials Engineering
Smith Engineering
Professor
Manufacturing automation, Machine vision for inspection, Pneumatic servosystems, Mechatronics education
Mechanical and Materials Engineering
Smith Engineering
PhD Candidate
Philosophy
University of Ottawa
Talia Cameron is a PhD candidate in Philosophy at the University of Ottawa and the Policy Research Lead at the Canadian Robotics and Artificial Intelligence Ethical Design Lab (CRAiEDL) under the supervision of Dr. Jason Millar, and Dr. Matthew Pan. Her research focuses on the ethics of AI and robotics in the context of climate change.
Date
Wednesday September 30, 2026ADVENTOR & Queen's Career Services is hosting a workshop- open to everyone!
Get ready to think strategically and re-organize your resumes, CVs, and cover letters to maximize your potential.
This workshop is geared to help aspiring robotic engineers translate their technical skills, experience, projects, and publications into clear and compelling tools to reach their career goals.
Join us in person, or online and learn how to put your best professional foot forward!
MASc Candidate
Mechanical Engineering
Queen's University
Tony Morales is an MASc candidate in Mechanical Engineering, under the supervision of Dr. Matthew Robertson, and Dr. Xian Wang. Tony also holds a B.Eng in Mechatronics and Robotics from Queen's University.
PhD Student
Mechanical Engineering
Queen's University
Nia Ralston is a PhD student under the supervision of Dr. Matthew Robertson and Dr. Tong Li (Zhejiang University). Nia specializes in humanoid and soft robotics, focusing on the mechanics of robotic walking.
Date
Tuesday August 18, 2026Location
Hybrid- Ingenuity Labs Floor 3Contact-rich manipulation requires compliant bodies for safe, adaptive interaction, yet remains challenging because robots must reason about real-world complexity and uncertainty in real time. Learning-based approaches have shown impressive effectiveness, and scaling laws suggest the power of more data, yet their internal mechanisms remain poorly understood. This talk presents a perspective on building structured intelligence for physical interaction. We begin with compliant and proprioceptive actuation for robotic manipulation, showing how soft-rigid hybrid structures can retain the safety and adaptability of soft materials while gaining the sensing, observability, and control precision needed for dexterous manipulation. We then examine structured tactile sensing and visual-tactile learning as ways to recover useful physical information from complex contact signals. Finally, we turn to robot learning: rather than assuming that more randomized data necessarily produces better policies, we propose the empirical Neural Tangent Kernel analysis to distinguish memorization, adaptation, and invariance to irrelevant variation. Across mechanism design, perception, and learning, we advance structure-conditioned intelligence: robot capabilities are shaped by physical structure in their bodies, their sensory representations, and their learning policies, enabling robust and generalizable manipulation.
Chao Liu is an Assistant Professor in the Department of Mechanical Engineering and an Associate Member in the Department of Computer Science at The University of British Columbia, Vancouver. Liu was a Postdoctoral Associate at the Computer Science and Artificial Intelligence Laboratory (CSAIL) at MIT, hosted by Daniela Rus. Before this, Liu completed his Ph.D. advised by Mark Yim at the ModLab, a part of the General Robotics, Automation, Sensing & Perception (GRASP) Laboratory at the University of Pennsylvania. His research focuses on bio-inspired robots, swarm and modular robots, parallel robots, robotic control and motion planning, and grasping and manipulation through multimodal sensing. His work includes the hardware design of several robotic platforms, novel perception solutions, and efficient algorithms on motion planning and control. Liu was the finalist for the Best Paper Award on Safety, Security, and Rescue Robotics in Memory of Motohiro Kisoi at IROS 2019.
Assistant Professor
Robotics and machine learning for motion planning, safe and reliable machine learning methods for robot arms and quadruped robots
CREATE ADVENTOR Supervisor
Electrical and Computer Engineering
McGill University
Associate Department Head
Developmental and Evolutionary Cognition
CREATE ADVENTOR Supervisor
Psychology
Queen's University
Arts and Science
Professor
Autonomous systems, assistive devices, service robots/ vehicles, robot-assisted emergency response, sensor agents, socially assistive robots
CREATE ADVENTOR Supervisor
Mechanical Engineering
The University of Toronto
Assistant Professor
Physical-social human-robot interaction, collaborative robots, privacy and cybersecurity in robotics, human motion analysis, optimal control
CREATE ADVENTOR Supervisor
Mechanical and Mechatronics Engineering
The University of Waterloo